End-to-end Autonomous Driving Research: status quo of End-to-end (E2E) autonomous driving
1. Status quo of end-to-end solutions in China
An end-to-end autonomous driving system refers to direct mapping from sensor data inputs (camera images, LiDAR, etc.) to control command outputs (steering, acceleration/deceleration, etc.). It first appeared in the ALVINN project in 1988. It uses cameras and laser rangefinders as input and a simple neural network to generate steering as output.
In early 2024, Tesla rolled out FSD V12.3, featuring an amazing intelligent driving level. The end-to-end autonomous driving solution garners widespread attention from OEMs and autonomous driving solution companies in China.?
Compared with conventional multi-module solutions, the end-to-end autonomous driving solution integrates perception, prediction and planning into a single model, simplifying the solution structure. It can simulate human drivers making driving decisions directly according to visual inputs, effectively cope with long tail scenarios of modular solutions and improve the training efficiency and performance of models.


Li Auto's end-to-end solution
Li Auto believes that a complete end-to-end model should cover the whole process of perception, tracking, prediction, decision and planning, and it is the optimal solution to achieve L3 autonomous driving. In 2023, Li Auto pushed AD Max3.0, with overall framework reflecting the end-to-end concept but still a gap with a complete end-to-end solution. In 2024, Li Auto is expected to promote the system to become a complete end-to-end solution.?
Li Auto's autonomous driving framework is shown below, consisting of two systems:
Fast system: System 1, Li Auto’s existing end-to-end solution which is directly executed after perceiving the surroundings.
Slow system: System 2, a multimodal large language model that logically thinks and explores unknown environments to solve problems in unknown L4 scenarios.

In the process of promoting the end-to-end solution, Li Auto plans to unify the planning/forecast model and the perception model, and accomplish the end-to-end Temporal Planner on the original basis to integrate parking with driving.
2. Data becomes the key to the implementation of end-to-end solutions.
The implementation of an end-to-end solution requires processes covering R&D team building, hardware facilities, data collection and processing, algorithm training and strategy customization, verification and evaluation, promotion and mass production. Some of the sore points in scenarios are as shown in the table:

The integrated training in end-to-end autonomous driving solutions requires massive data, so one of the difficulties it faces lies in data collection and processing.
First of all, it needs a long time and may channels to collect data, including driving data and scenario data such as roads, weather and traffic conditions. In actual driving, the data within the driver's front view is relatively easy to collect, but the surrounding information is hard to say.
During data processing, it is necessary to design data extraction dimensions, extract effective features from massive video clips, make statistics of data distribution, etc. to support large-scale data training.
DeepRoute
As of March 2024, DeepRoute.ai's end-to-end autonomous driving solution has been designated by Great Wall Motor and involved in the cooperation with NVIDIA. It is expected to adapt to NVIDIA Thor in 2025. In the planning of DeepRoute.ai, the transition from the conventional solution to the "end-to-end" autonomous driving solution will go through sensor pre-fusion, HD map removal, and integration of perception, decision and control.

GigaStudio
DriveDreamer, an autonomous driving model of GigaStudio, is capable of scenario generation, data generation, driving action prediction and so forth. In the scenario/data generation, it has two steps:
When involving single-frame structural conditions, guide DriveDreamer to generate driving scenario images, so that it can understand structural traffic constraints easily.
Extend its understanding to video generation. Using continuous traffic structure conditions, DriveDreamer outputs driving scene videos to further enhance its understanding of motion transformation.

3. End-to-end solutions accelerate the application of embodied robots.
In addition to autonomous vehicles, embodied robots are another mainstream scenario of end-to-end solutions. From end-to-end autonomous driving to robots, it is necessary to build a more universal world model to adapt to more complex and diverse real application scenarios. The development framework of mainstream AGI (General Artificial Intelligence) is divided into two stages:
Stage 1: the understanding and generation of basic foundation models are unified, and further combined with embodied artificial intelligence (embodied AI) to form a unified world model;
Stage 2: capabilities of world model + complex task planning and control, and abstract concept induction gradually evolve into the era of the interactive AGI 1.0.
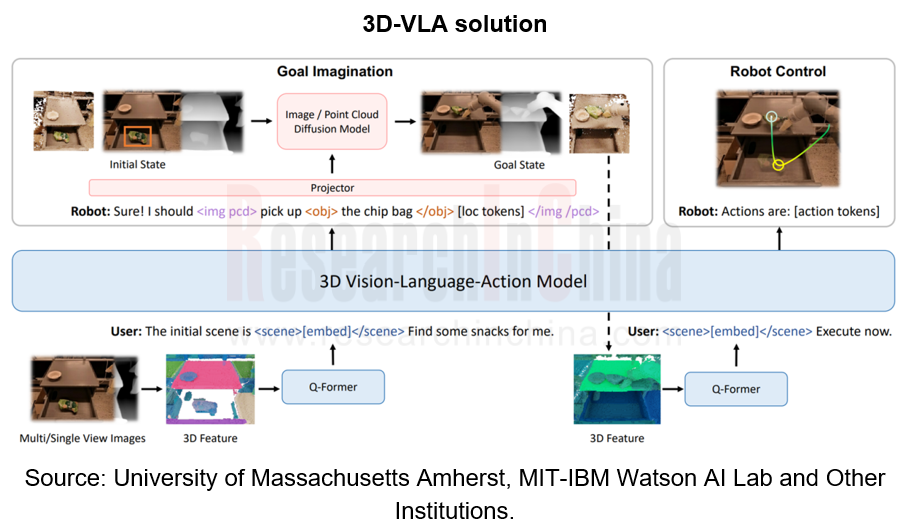
In the landing process of the world model, the construction of an end-to-end VLA (Vision-Language-Action) autonomous system has become a crucial link. VLA, as the basic foundation model of embodied AI, can seamlessly link 3D perception, reasoning and action to form a generative world model, which is built on the 3D-based large language model (LLM) and introduces a set of interactive markers to interact with the environment.
As of April 2024, some manufacturers of humanoid robots adopting end-to-end solutions are as follows:

For example, Udeer·AI's Large Physical Language Model (LPLM) is an end-to-end embodied AI solution that uses a self-labeling mechanism to improve the learning efficiency and quality of the model from unlabeled data, thereby deepening the understanding of the world and enhancing the robot's generalization capabilities and environmental adaptability in cross-modal, cross-scene, and cross-industry scenarios.

LPLM abstracts the physical world and ensures that this kind of information is aligned with the abstract level of features in LLM. It explicitly models each entity in the physical world as a token, and encodes geometric, semantic, kinematic and intentional information.
In addition, LPLM adds 3D grounding to the encoding of natural language instructions, improving the accuracy of natural language to some extent. Its decoder can learn by constantly predicting the future, thus strengthening the ability of the model to learn from massive unlabeled data.
Automotive Microcontroller Unit (MCU) and Application Scenario Research Report, 2026
Automotive MCU Research: Increased demand for redundant security drives ASIL D-compliant MCU shipments to exceed 100 million units
In a vehicle EEA, MCUs are widely distributed in various functional ...
China Intelligent Cockpit Patent Analysis Report, 2026
Intelligent Cockpit Patent Research: Cockpit AI, In?vehicle Health, and Infotainment Are Upgrade to Scenario?based and Proactive Functions
From a patent perspective, this report explores the cutting?...
Research Report on Application of VLA Large Model in Automobiles and Robots, 2026
Research on Automotive and Robot VLA: Hybrid Architectures Become Mainstream, VLA Integrates with General World Models, and Reinforcement Learning Serves as Core Engine
Vision?Language?Action (VLA) m...
China Charging Infrastructure (Supercharging, Battery Swapping, V2G, etc.) and High-Performance Supercharging Battery Research Report, 2026
Charging and battery swapping research: as 5C+ supercharging vehicle models go into mass production, the pace of OEMs self-building supercharging networks quickens
800-1000V high-voltage platforms ar...
China Passenger Car Electronic Controlled Suspension Industry Report, 2026
Electronic Controlled Suspension Industry Research: As the First Year of Full Active Suspension Unfolds, Three Technical Routes Race Forward
1. Penetration Rate Surges Three Times, and Electronic Con...
Intelligent Driving SoC Research Report, 2026
Research on Intelligent Driving SoCs: Competition Focus Shifts to L3/L4 Embedded Hardware, and Computing Power of Flagship Vehicle Models Exceeds 1,000 TOPS
In terms of intelligent driving system in...
Automotive AI Large Model Technology Research Report, 2026
Automotive AI Large Model Research: Competition Shifts from "Who Has the Stronger Model" to "Who Boasts Higher Link Efficiency"
ResearchInChina released the Automotive AI Large Model Technology Resea...
Intelligent Vehicle Cockpit Domain Controller Research Report, 2026
Cockpit domain controller research: L3 AIDV intelligent cockpit domain controllers are entering a boom period
Driven by multiple factors such as the continuous evolution of the automotive central int...
Automotive Acoustic System (Audio, Multi-Channel) Industry Report, 2026
Automotive Acoustics Research: Multiple Channels, AI Tuning, and Self-Developed Algorithms Drive the Transformation of High-End Cockpit Sound Fields
I. Automotive Audio Hardware Solutions with 6–9 S...
Autonomous Driving Sensor Chip Research Report, 2026
Research on Autonomous Driving Sensor Chips: Deeply Perceiving the Physical World, Sensor Chips Are Playing A “Leading Role” in Intelligence
In 2026, the autonomous driving sensor chip industr...
Passenger Car Corner Module and Wheel‑Side Control System Research Report, 2026
Wheel-side control research: the “last mile” chassis innovation
Wheel-side control dismantles the traditional drive, braking, steering, and suspension control of the chassis from a "centralized" styl...
Embodied Artificial Intelligence (& Humanoid Robot) MCU Research Report, 2026
Research on Humanoid Robot MCUs: Evolution from General-Purpose Control to High-Value Dedicated Chip Solutions Integrated with Edge AI Functions
MCU (Microcontroller Unit) refers to a compact integra...
Intelligent Vehicle Zone Control Unit (ZCU) Research Report, 2026
ZCU Research: Cross-domain integrated ZCUs are becoming the edge computing nodes of the next-generation zonal architecture
Currently, the mainstream zonal architecture is mainly the quasi-central + z...
Automotive Cybersecurity and Data Security Research Report, 2026
Cybersecurity & Data Security Research: Intelligent Connected Vehicles Enter the Era of “Systematic Offense-Defense and AI-Defined Security”.
Centering on the panorama of intelligent connect...
Report on Breakthrough Strategies of OEMs and ADAS Tier 1 Suppliers for Overseas Layout of Intelligent Driving, 2026
Regulatory Breakthrough, Local System Establishment, OEMs Competing for NOA Layout: Overall Trends of China’s Intelligent Driving Overseas Layout in 2026
Research on overseas intelligent driving layo...
OEMs and Tier1s’ Intelligent Cockpit Platform (Hardware and Software) Innovation Strategy Research Report, 2026
Intelligent Cockpit Platform Research: multi-dimensional cockpit system architecture reconstruction for multi-agent collaboration and proactive intelligent services
The intelligent cockpit software s...
Automotive AIOS Research Report, 2026
Automotive AIOS Research: Mass Production Solutions Are Implemented
Mass Production Solutions Are Implemented on A Small Scale.
In 2026, AIOS starts small-scale implementation, helping to improve v...
Automotive Telematics Service Provider (TSP) Research Report, 2026
TSP Research: Leading providers collectively turn to AI agents to provide all-scenario active services
Telematics Service Providers (TSPs) are the core hub of the telematics industry chain, connectin...